LogoMicro Planetary Motor
Start inquiry
LogoMicro Planetary Motor
WhatsApp
LogoMicro Planetary Motor

China-based industrial OEM supplier supporting customization, quality control, and global delivery.

Inquiry Email

[email protected]

Email app

Include OD/length, voltage, torque, loaded speed, ratio, drawings, quantity, and destination.

Instant Chat

+86 18857971991

Chat on WhatsApp

Fast channel for clarifying specs, drawings, and sample timing.

Products
  • Product Overview
  • Micro DC Planetary Gear Motor
  • Micro BLDC Planetary Gear Motor
  • Encoder Micro Planetary Gear Motor
  • Miniature Planetary Gearboxes
  • Custom OEM Drive Assemblies
  • Coreless Micro Planetary Motors
  • Low Backlash Planetary Motors
  • Low Noise Micro Planetary Motors
  • High Torque Miniature Motors
  • Metal Gear Planetary Drives
Solutions
  • Solutions Overview
  • Robotics & AGV
  • Medical Devices
  • Smart Lock Actuators
  • Valve Actuators
  • Optical Instruments
  • Industrial Automation
OEM Capabilities
  • OEM Overview
  • Custom Engineering
  • Gear Machining
  • Testing & Validation
  • Export & Logistics
Resources
  • CAD / STEP Request
  • Ratio & Torque Calculator
  • POM vs MIM Gear Materials
  • Premium Brand Alternatives
  • Blog
  • About
  • Contact / RFQ
  • Quality & Testing
  • Privacy Policy
  • Cookie Policy
  • Terms of Service
© 2026 Micro Planetary Motor. All Rights Reserved.|Micro Planetary Motor is the micro drive product site operated by Linkup Ai Co., Ltd.; manufacturing programs are coordinated through the Linkup Precision manufacturing network.|Traceable process checks | RoHS, REACH, and applicable CE file support by project scope
← Back to Products

Encoder Micro Planetary Gear Motor

Closed-loop micro planetary gear motors with magnetic or optical feedback for OEM motion systems that need measurable speed, direction, homing, or positioning data instead of open-loop timing assumptions.

Target Buyer:Best for robotics, automation, optics, and actuator teams that need supplier-supported feedback resolution, wiring control, and acceptance tests for repeatable movement.
Discuss on WhatsAppSend RFQEmail specsRequest CAD / STEP

OEM pricing, sample terms, freight, and lead time are confirmed by RFQ after drawings, quantity, destination, and validation scope are reviewed.
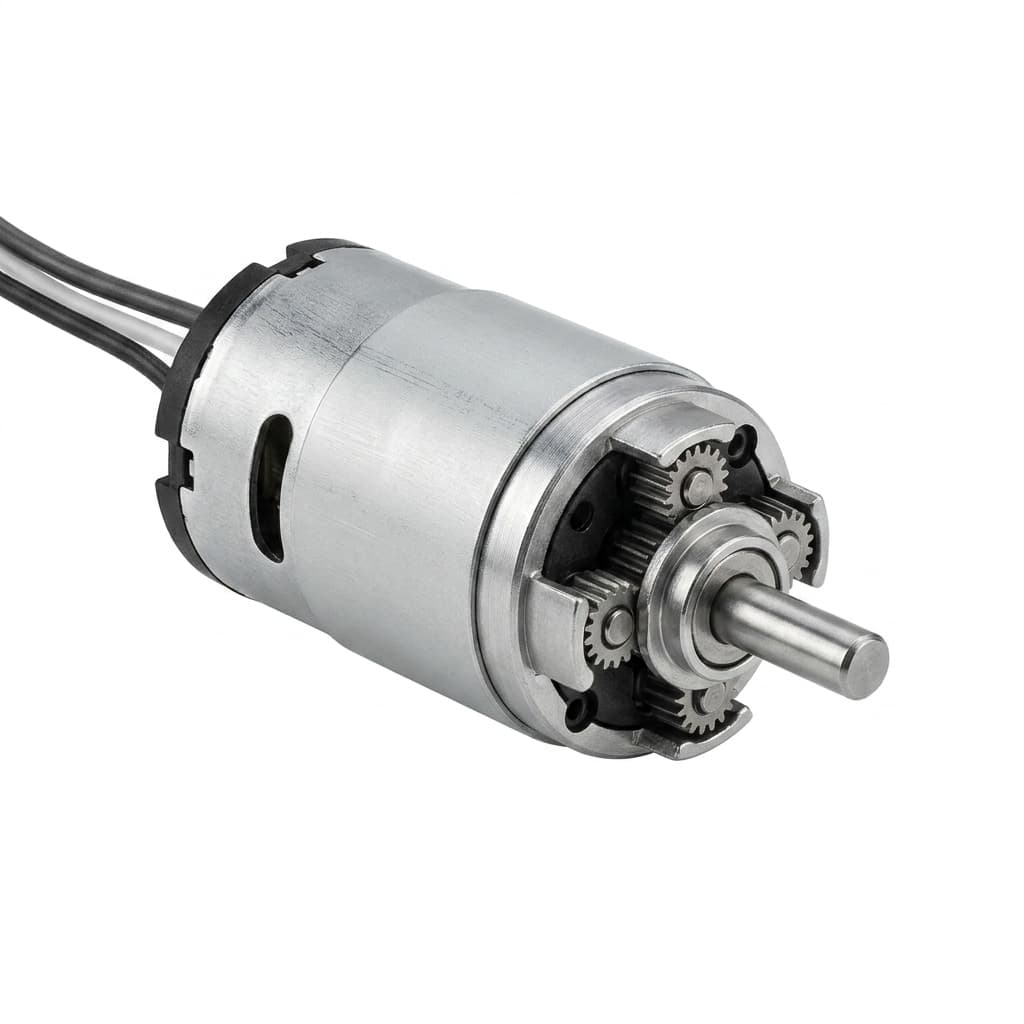
Encoder micro planetary gear motor with rear feedback module for closed-loop control

Commercial Availability

RFQ Terms for Encoder Micro Planetary Gear Motor

Unit pricing, sample terms, freight, and lead time are confirmed by RFQ after drawings, quantity, destination, annual volume, and validation scope are reviewed.

FieldCurrent Page ValueBuyer Use
Product codeMPM-ENCODER-MICRO-PLANETARY-GEAR-MOTORPage-level product family identifier used to keep RFQ, drawing, sample, and quote communication aligned.
Commercial pathRFQ-based OEM quotationNo public checkout price is shown because winding, ratio, gear material, shaft, validation evidence, freight, and volume change the final unit cost.
Offer statusPlatform-dependent availabilityStandard micro planetary motor platforms are reviewed for custom sampling and production fit before quote confirmation.
ConditionNew OEM components and assembliesSamples and production lots are treated as new industrial components tied to the approved drawing revision and buyer file.
Valid fromAugust 5, 2026This page describes the current RFQ route; written quotations state their own price validity, incoterm, and lead-time assumptions.
RegionWorldwide RFQ supportDestination, compliance needs, packing notes, and shipping route are confirmed during quotation instead of embedded as a fixed retail shipping rate.
Quote currencyUSDExport quotations are usually discussed in USD unless a buyer requests another quotation currency.

Product code

Current Page Value
MPM-ENCODER-MICRO-PLANETARY-GEAR-MOTOR
Buyer Use
Page-level product family identifier used to keep RFQ, drawing, sample, and quote communication aligned.

Commercial path

Current Page Value
RFQ-based OEM quotation
Buyer Use
No public checkout price is shown because winding, ratio, gear material, shaft, validation evidence, freight, and volume change the final unit cost.

Offer status

Current Page Value
Platform-dependent availability
Buyer Use
Standard micro planetary motor platforms are reviewed for custom sampling and production fit before quote confirmation.

Condition

Current Page Value
New OEM components and assemblies
Buyer Use
Samples and production lots are treated as new industrial components tied to the approved drawing revision and buyer file.

Valid from

Current Page Value
August 5, 2026
Buyer Use
This page describes the current RFQ route; written quotations state their own price validity, incoterm, and lead-time assumptions.

Region

Current Page Value
Worldwide RFQ support
Buyer Use
Destination, compliance needs, packing notes, and shipping route are confirmed during quotation instead of embedded as a fixed retail shipping rate.

Quote currency

Current Page Value
USD
Buyer Use
Export quotations are usually discussed in USD unless a buyer requests another quotation currency.

Capability Highlights

  • Precise speed and position feedback
  • Dual channel quadrature output
  • Compact integration

Typical Applications

  • AGV/AMR Drives
  • Precision Optics
  • Automated Valves
  • Metering and indexing modules
  • Robotic service mechanisms

Engineering Focus

  • Encoder resolution (CPR) matching
  • Signal integrity and wiring harness
  • Backlash management
  • Motor-side versus output-side feedback tradeoff
  • Controller logic level and noise immunity

OEM Buyer Decision Path

Qualify the Product Across Engineering, Procurement, and QA

Product selection usually fails when only one team reviews the motor. Use this path to connect mechanical fit, quote scope, validation evidence, and production handoff before sample approval.

Buyer RoleDecision CheckPage EvidenceNext Step
Design EngineeringEnvelope, output speed, continuous torque, stall condition, backlash/noise limit, shaft datum, and cable route.Performance window, engineering focus, customization map, CAD/STEP request path, and material review.Request CAD / STEP
ProcurementPrototype quantity, annual volume, destination, sample timing, quote scope, and approved supplier workflow.RFQ checklist, email template, WhatsApp handoff, and quote caveat before sample pricing.Send RFQ
QualityIncoming CTQ, drawing revision, torque-speed test condition, noise/backlash method, and lot traceability expectation.Risk controls, validation scope, buyer file package, and quality evidence review path.Review Quality
OEM ProgramNPI stage, frozen BOM fields, custom tooling boundary, packing rules, revision control, and production handoff.OEM customization options, supplier workflow, export coordination, and related application routing.OEM Workflow

Design Engineering

Decision Check
Envelope, output speed, continuous torque, stall condition, backlash/noise limit, shaft datum, and cable route.
Page Evidence
Performance window, engineering focus, customization map, CAD/STEP request path, and material review.
Next Step
Request CAD / STEP

Procurement

Decision Check
Prototype quantity, annual volume, destination, sample timing, quote scope, and approved supplier workflow.
Page Evidence
RFQ checklist, email template, WhatsApp handoff, and quote caveat before sample pricing.
Next Step
Send RFQ

Quality

Decision Check
Incoming CTQ, drawing revision, torque-speed test condition, noise/backlash method, and lot traceability expectation.
Page Evidence
Risk controls, validation scope, buyer file package, and quality evidence review path.
Next Step
Review Quality

OEM Program

Decision Check
NPI stage, frozen BOM fields, custom tooling boundary, packing rules, revision control, and production handoff.
Page Evidence
OEM customization options, supplier workflow, export coordination, and related application routing.
Next Step
OEM Workflow

Key Evaluation Matrix

MetricTypical RangeWhy It Matters
Encoder CPR3 - 1000 CPRDictates the positioning resolution capability of the system.
Output ChannelsDual Channel (A/B) QuadratureEnables both speed measurement and directional sensing.
Input Voltage (Vcc)3.3V or 5.0VMust match your MCU logic level to avoid blowing the sensor.

Encoder CPR

Typical Range
3 - 1000 CPR
Why It Matters
Dictates the positioning resolution capability of the system.

Output Channels

Typical Range
Dual Channel (A/B) Quadrature
Why It Matters
Enables both speed measurement and directional sensing.

Input Voltage (Vcc)

Typical Range
3.3V or 5.0V
Why It Matters
Must match your MCU logic level to avoid blowing the sensor.

Ratio & Performance Window

Reference Performance Table by Frame and Ratio

These RFQ reference windows translate the planning ranges into an engineering shortlist. Final datasheet values are confirmed by winding, ratio, gear material, load, duty cycle, current limit, and test condition before sample approval.

Frame / ODRated VoltageRatio RangeNo-load RPMRated-load RPMContinuous Output TorqueStall TorqueEfficiencyApplication Fit
10/12mm encoder gearmotor3-12V motor; 3.3V or 5V encoder5:1-1000:1Quote from motor RPM, CPR, and controller inputConfirm pulse rate at target loaded output RPM100 g.cm-1.5 kg.cm reference windowJam limit must protect gears and encoder PCBGear stage count plus sensor load dependentSmart locks, optics, compact automation
16/22mm encoder gearmotor6-24V motor; 3.3V or 5V encoder4:1-1500:1Motor winding dependent; verify pulse bandwidthSet by closed-loop speed and load curve0.5-5.5 Nm reference windowConfirm overload, homing, and current cutoffRatio, bearing load, and feedback wiring dependentAGV modules, valves, robot joints
36/42mm encoder BLDC option24-48V BLDC with feedback3:1-512:1Driver and feedback bandwidth reviewed togetherValidated at loaded wheel or actuator speed9.3-35 Nm reference windowDriver, shaft, and gearbox protection requiredOptimized around BLDC drive and stage countAGV wheels, steering axes, heavy actuators

10/12mm encoder gearmotor

Rated Voltage
3-12V motor; 3.3V or 5V encoder
Ratio Range
5:1-1000:1
No-load RPM
Quote from motor RPM, CPR, and controller input
Rated-load RPM
Confirm pulse rate at target loaded output RPM
Continuous Output Torque
100 g.cm-1.5 kg.cm reference window
Stall Torque
Jam limit must protect gears and encoder PCB
Efficiency
Gear stage count plus sensor load dependent
Application Fit
Smart locks, optics, compact automation

16/22mm encoder gearmotor

Rated Voltage
6-24V motor; 3.3V or 5V encoder
Ratio Range
4:1-1500:1
No-load RPM
Motor winding dependent; verify pulse bandwidth
Rated-load RPM
Set by closed-loop speed and load curve
Continuous Output Torque
0.5-5.5 Nm reference window
Stall Torque
Confirm overload, homing, and current cutoff
Efficiency
Ratio, bearing load, and feedback wiring dependent
Application Fit
AGV modules, valves, robot joints

36/42mm encoder BLDC option

Rated Voltage
24-48V BLDC with feedback
Ratio Range
3:1-512:1
No-load RPM
Driver and feedback bandwidth reviewed together
Rated-load RPM
Validated at loaded wheel or actuator speed
Continuous Output Torque
9.3-35 Nm reference window
Stall Torque
Driver, shaft, and gearbox protection required
Efficiency
Optimized around BLDC drive and stage count
Application Fit
AGV wheels, steering axes, heavy actuators

Sample Acceptance Plan

Turn Product Selection Into Pass/Fail Checks

Before a motor family becomes a sample order, sales engineering converts the RFQ into acceptance checks for engineering, procurement, and quality. These checks keep CAD/STEP release, prototype approval, and repeat production tied to the same specification baseline.

WorkstreamBuyer QuestionEvidence to PreparePass Signal
Encoder resolutionDoes the CPR/PPR target give enough control resolution after gearbox reduction?Position tolerance, controller count rate, target RPM range, PPR/CPR preference, and logic voltage.Measured counts, direction, and low-speed resolution satisfy the control-loop requirement.
Homing and jam behaviorCan the system detect end stops, missed motion, or reversal without false position confidence?Homing sequence, jam current threshold, reversal frequency, controller logic, and backlash allowance.The sample identifies direction, jam events, and repeatable home position under load.
Cable and signal integrityWill encoder signals stay clean through the final harness and connector route?Cable length, connector family, shielding, pull-up values, MCU voltage, and nearby EMI sources.A/B pulses remain clean at the required speed with no connector dropout or false counts.
Mechanical accuracy stackIs the positioning error dominated by gearbox backlash, encoder resolution, or linkage tolerance?Backlash limit, shaft coupling, mounting datum, load direction, and repeatability target.Output repeatability is measured at the load condition the buyer will use for acceptance.

Encoder resolution

Buyer Question
Does the CPR/PPR target give enough control resolution after gearbox reduction?
Evidence to Prepare
Position tolerance, controller count rate, target RPM range, PPR/CPR preference, and logic voltage.
Pass Signal
Measured counts, direction, and low-speed resolution satisfy the control-loop requirement.

Homing and jam behavior

Buyer Question
Can the system detect end stops, missed motion, or reversal without false position confidence?
Evidence to Prepare
Homing sequence, jam current threshold, reversal frequency, controller logic, and backlash allowance.
Pass Signal
The sample identifies direction, jam events, and repeatable home position under load.

Cable and signal integrity

Buyer Question
Will encoder signals stay clean through the final harness and connector route?
Evidence to Prepare
Cable length, connector family, shielding, pull-up values, MCU voltage, and nearby EMI sources.
Pass Signal
A/B pulses remain clean at the required speed with no connector dropout or false counts.

Mechanical accuracy stack

Buyer Question
Is the positioning error dominated by gearbox backlash, encoder resolution, or linkage tolerance?
Evidence to Prepare
Backlash limit, shaft coupling, mounting datum, load direction, and repeatability target.
Pass Signal
Output repeatability is measured at the load condition the buyer will use for acceptance.

Selection-Ready Product Data

Build the Ratio Table Before Sample Approval

Public diameter pages are only the starting point. For RFQ review, sales engineering confirms rated voltage, no-load RPM, rated-load RPM, continuous output torque, stall torque, current, efficiency, and gear ratio against your mechanism before releasing drawings or sample pricing.

Performance FieldBuyer InputHow It Shapes the Quote
Rated voltage and current limit3V, 6V, 12V, 24V, or buyer-defined driver limitSelects the winding, thermal margin, stall-current boundary, and battery or adapter fit.
No-load speed and loaded output speedMotor RPM, target output RPM, and acceptable speed toleranceNarrows the gear ratio and keeps the prototype inside the required actuation time.
Continuous output torque and stall torqueWorking torque, peak load, jam condition, and stall durationChecks gear material, shaft support, carrier strength, and safety margin before sampling.
Gear ratio and efficiency targetKnown ratio, output RPM target, or torque-speed curve from the mechanismBuilds the ratio table used to compare speed, torque, current, efficiency, and heat rise.
Duty cycle and life targetOn/off sequence, cycles per day, lifetime cycles, ambient temperatureDefines grease, gear stack, winding temperature, brush life, and sample validation scope.
Noise and backlash limitdB limit, measurement distance, arcmin or degree target, load fixtureSeparates POM, hybrid, metal, and low-backlash options before the CAD exchange.

Rated voltage and current limit

Buyer Input
3V, 6V, 12V, 24V, or buyer-defined driver limit
How It Shapes the Quote
Selects the winding, thermal margin, stall-current boundary, and battery or adapter fit.

No-load speed and loaded output speed

Buyer Input
Motor RPM, target output RPM, and acceptable speed tolerance
How It Shapes the Quote
Narrows the gear ratio and keeps the prototype inside the required actuation time.

Continuous output torque and stall torque

Buyer Input
Working torque, peak load, jam condition, and stall duration
How It Shapes the Quote
Checks gear material, shaft support, carrier strength, and safety margin before sampling.

Gear ratio and efficiency target

Buyer Input
Known ratio, output RPM target, or torque-speed curve from the mechanism
How It Shapes the Quote
Builds the ratio table used to compare speed, torque, current, efficiency, and heat rise.

Duty cycle and life target

Buyer Input
On/off sequence, cycles per day, lifetime cycles, ambient temperature
How It Shapes the Quote
Defines grease, gear stack, winding temperature, brush life, and sample validation scope.

Noise and backlash limit

Buyer Input
dB limit, measurement distance, arcmin or degree target, load fixture
How It Shapes the Quote
Separates POM, hybrid, metal, and low-backlash options before the CAD exchange.

Customization Options

Match the Motor to the Mechanical Boundary

The useful custom scope is normally around the shaft, gearbox stack, feedback, cable exit, connector, and buyer file package. These options should be fixed before tooling, CAD exchange, or pilot builds.

Custom AreaCommon OptionsRFQ Signal
Output shaft and mountingD-cut, flat, threaded, cross-drilled, keyway, custom length, flange, bearing support.Attach shaft datum, mating part drawing, radial/axial load direction, and installation sequence.
Gear material and backlashPOM, MIM, machined metal, hybrid stages, grease selection, low-backlash build review.State torque peaks, reversing frequency, noise target, temperature, and life requirement.
Feedback and controlEncoder, Hall signal, EMI suppression, pinout, driver match, current-limit review.Share CPR, signal voltage, controller type, cable route, connector drawing, and EOL test needs.
Cable, connector, and assemblyLead wire length, connector model, cable exit, strain relief, bracket, harness, module assembly.Include enclosure envelope, bend radius, pull-force concern, label rules, and packing notes.
Compliance and buyer fileRoHS/REACH file, material note, drawing revision, sample test report, lot traceability.Confirm destination, regulated-market expectations, incoming inspection plan, and annual volume.

Output shaft and mounting

Common Options
D-cut, flat, threaded, cross-drilled, keyway, custom length, flange, bearing support.
RFQ Signal
Attach shaft datum, mating part drawing, radial/axial load direction, and installation sequence.

Gear material and backlash

Common Options
POM, MIM, machined metal, hybrid stages, grease selection, low-backlash build review.
RFQ Signal
State torque peaks, reversing frequency, noise target, temperature, and life requirement.

Feedback and control

Common Options
Encoder, Hall signal, EMI suppression, pinout, driver match, current-limit review.
RFQ Signal
Share CPR, signal voltage, controller type, cable route, connector drawing, and EOL test needs.

Cable, connector, and assembly

Common Options
Lead wire length, connector model, cable exit, strain relief, bracket, harness, module assembly.
RFQ Signal
Include enclosure envelope, bend radius, pull-force concern, label rules, and packing notes.

Compliance and buyer file

Common Options
RoHS/REACH file, material note, drawing revision, sample test report, lot traceability.
RFQ Signal
Confirm destination, regulated-market expectations, incoming inspection plan, and annual volume.

Evidence Pack Before Sampling

Evidence Pack to Request Before Sampling

These files are normally reviewed by request rather than downloaded instantly. Confirm the scope early so drawings, sample data, quality records, and production notes match the same motor revision.

Evidence ItemWhat to RequestWhy It MattersRoute
CAD / STEP baselineOuter diameter, length, shaft geometry, flange datum, connector clearance, and mating-part constraints.Prevents a mechanically suitable motor from failing because of envelope, shaft, or mounting mismatch.CAD request
Torque-speed-current windowRated voltage, no-load speed, rated-load speed, continuous torque, stall torque, current limit, and duty cycle.Separates reference catalog windows from the sample value set that purchasing and engineering can approve.RFQ template
Inspection and test evidenceDimensional CTQ, gear ratio check, no-load current, load test, noise/backlash method, and final inspection record.Lets the buyer define what must be proven before incoming inspection, pilot build, or supplier approval.Quality review
Gear material and backlash routePOM, hybrid, or metal stage choice, grease condition, reversing motion, temperature, shock load, and noise target.Aligns durability, acoustic behavior, backlash, cost, and life expectation before the sample BOM is frozen.Material guide
OEM handoff packageDrawing revision, cable/connector rules, label and packing notes, destination, compliance file needs, and annual volume.Turns a selected sample into a production-ready supplier package with fewer revision loops.OEM workflow

CAD / STEP baseline

What to Request
Outer diameter, length, shaft geometry, flange datum, connector clearance, and mating-part constraints.
Why It Matters
Prevents a mechanically suitable motor from failing because of envelope, shaft, or mounting mismatch.
Route
CAD request

Torque-speed-current window

What to Request
Rated voltage, no-load speed, rated-load speed, continuous torque, stall torque, current limit, and duty cycle.
Why It Matters
Separates reference catalog windows from the sample value set that purchasing and engineering can approve.
Route
RFQ template

Inspection and test evidence

What to Request
Dimensional CTQ, gear ratio check, no-load current, load test, noise/backlash method, and final inspection record.
Why It Matters
Lets the buyer define what must be proven before incoming inspection, pilot build, or supplier approval.
Route
Quality review

Gear material and backlash route

What to Request
POM, hybrid, or metal stage choice, grease condition, reversing motion, temperature, shock load, and noise target.
Why It Matters
Aligns durability, acoustic behavior, backlash, cost, and life expectation before the sample BOM is frozen.
Route
Material guide

OEM handoff package

What to Request
Drawing revision, cable/connector rules, label and packing notes, destination, compliance file needs, and annual volume.
Why It Matters
Turns a selected sample into a production-ready supplier package with fewer revision loops.
Route
OEM workflow

Gear Material Review

Confirm POM, Hybrid, or Metal Stages Before Prototype Approval

Use the material guide to align noise, torque density, stall load, wear, grease, and backlash expectations before the sample BOM is frozen.

Compare POM vs MIM gears

CAD / STEP Request

Request Outline Drawings Before You Freeze the Mechanical Design

Share the mating envelope and target duty data so sales engineering can confirm whether an existing outline drawing, STEP/IGES file, or custom shaft and flange proposal is suitable for your project.

1

Installation envelope, mounting pattern, shaft interface, and cable exit.

2

Voltage, loaded speed, torque, gear ratio, duty cycle, noise, and backlash limits.

3

Preferred CAD format, drawing revision, prototype quantity, destination, and compliance notes.

Fields engineering checks before sharing a model

Product fit
Diameter, gearbox length, motor family, shaft style, flange pattern, and cable or connector exit.
Performance target
Voltage, loaded speed, continuous torque, peak or stall torque, ratio, duty cycle, life, noise, and backlash.
Mechanical interface
Mating drawing revision, installation clearance, radial or axial load, tolerance priority, and assembly sequence.
Release package
2D outline, STEP/IGES envelope, custom shaft/flange review, datasheet values, and quality evidence scope.

Useful before CAD freeze

Estimate ratio and torque firstCompare POM, hybrid, and metal gearsAlign quality evidence scope
Email CAD requestWhatsApp engineeringOpen CAD request form

CAD files are shared by project fit and revision status. For custom shafts, flanges, cable routing, or gearbox interfaces, attach the mating drawing so the first CAD exchange uses the correct mechanical boundary.
RFQ Checklist

  1. Required Pulses Per Revolution (PPR)
  2. Target positioning accuracy
  3. Connector type and pinout
  4. Logic voltage, output channel type, and cable length
  5. Whether feedback is required on motor shaft or output shaft
  6. Backlash, homing, and repeatability test method

Risk Controls

  • Signal interference (EMI): Use shielded cables and proper grounding in the wiring harness.
  • Pulse jitter at low speeds: We tune the magnetic pole clearance and use high-grade Hall ICs to ensure clean square waves.
  • Vibration induced disconnects: All encoder PCBs are conformal coated and use locking JST/Molex connectors.
  • Motor-side feedback hides gearbox lost motion: For precise output positioning, backlash, mounting stiffness, homing logic, and optional output-side sensing are reviewed together.

Product Gallery

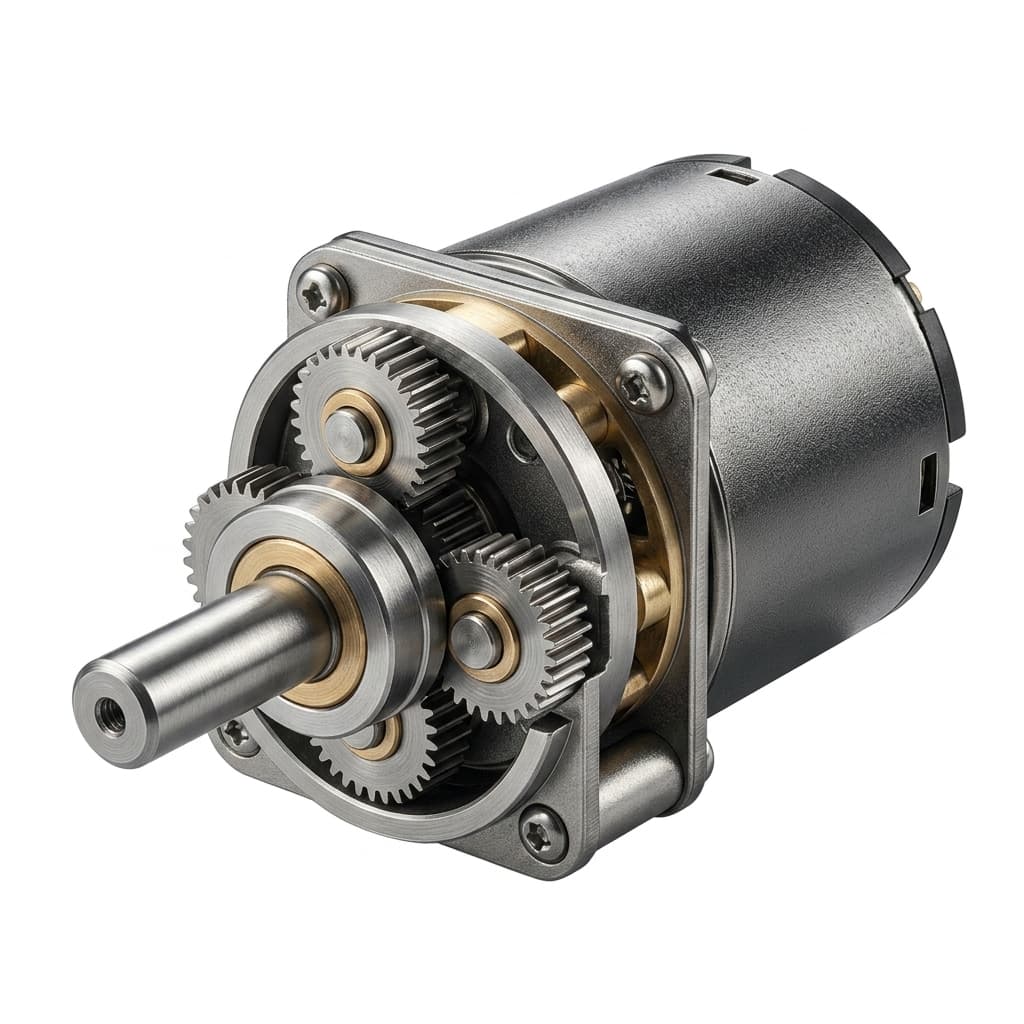
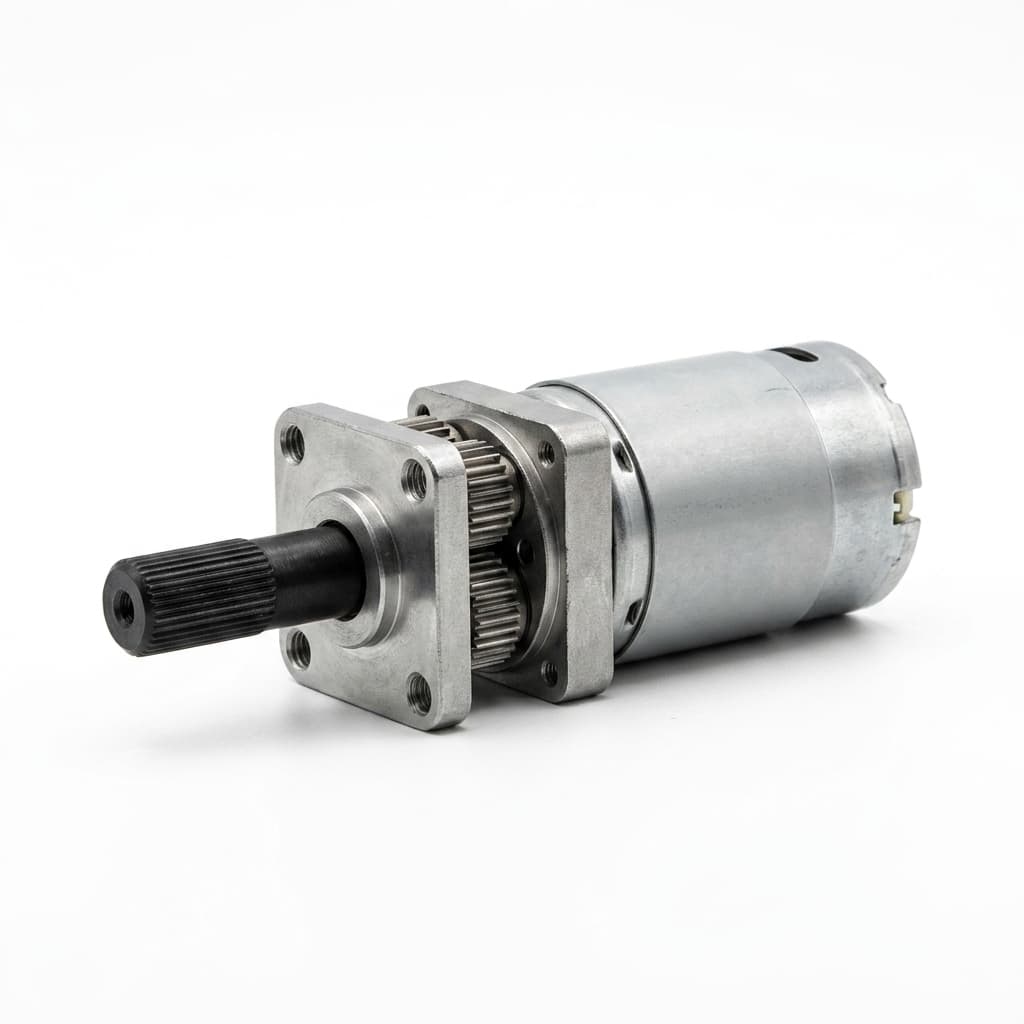
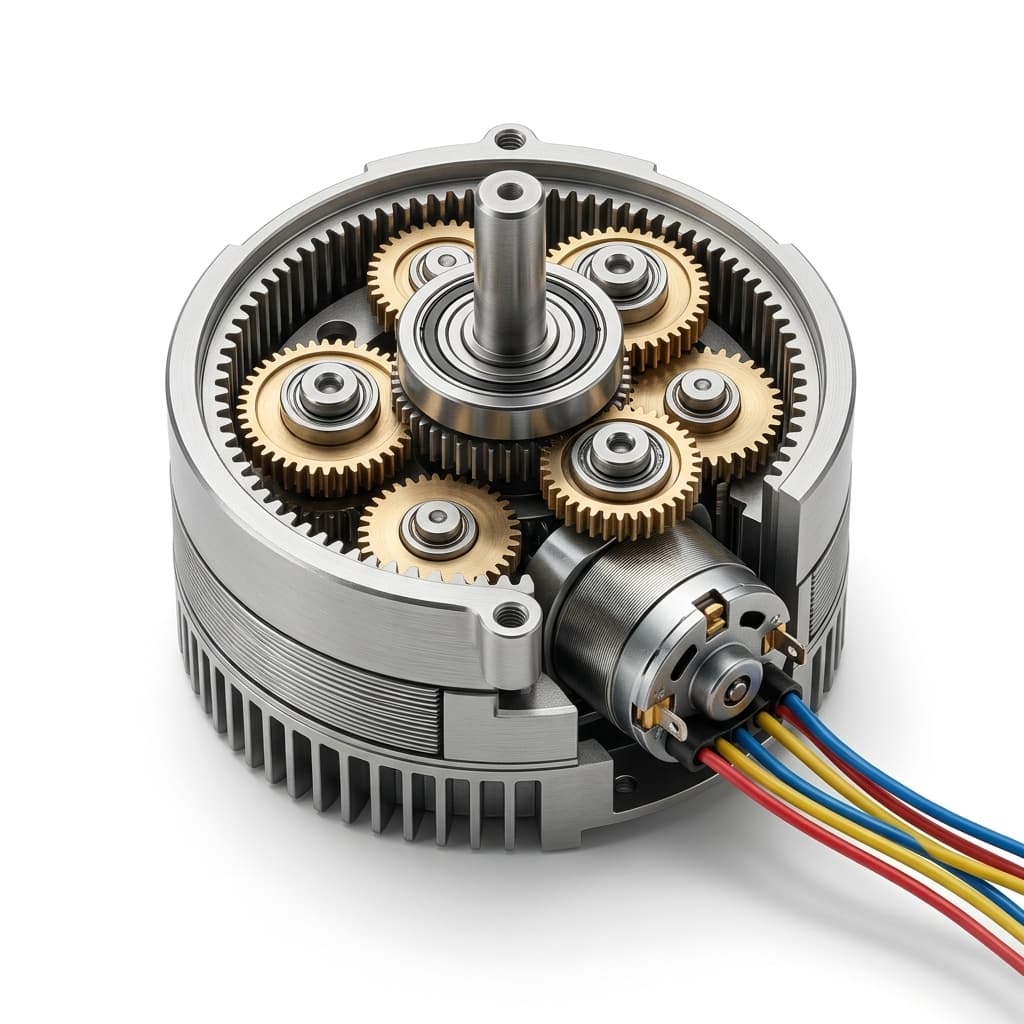
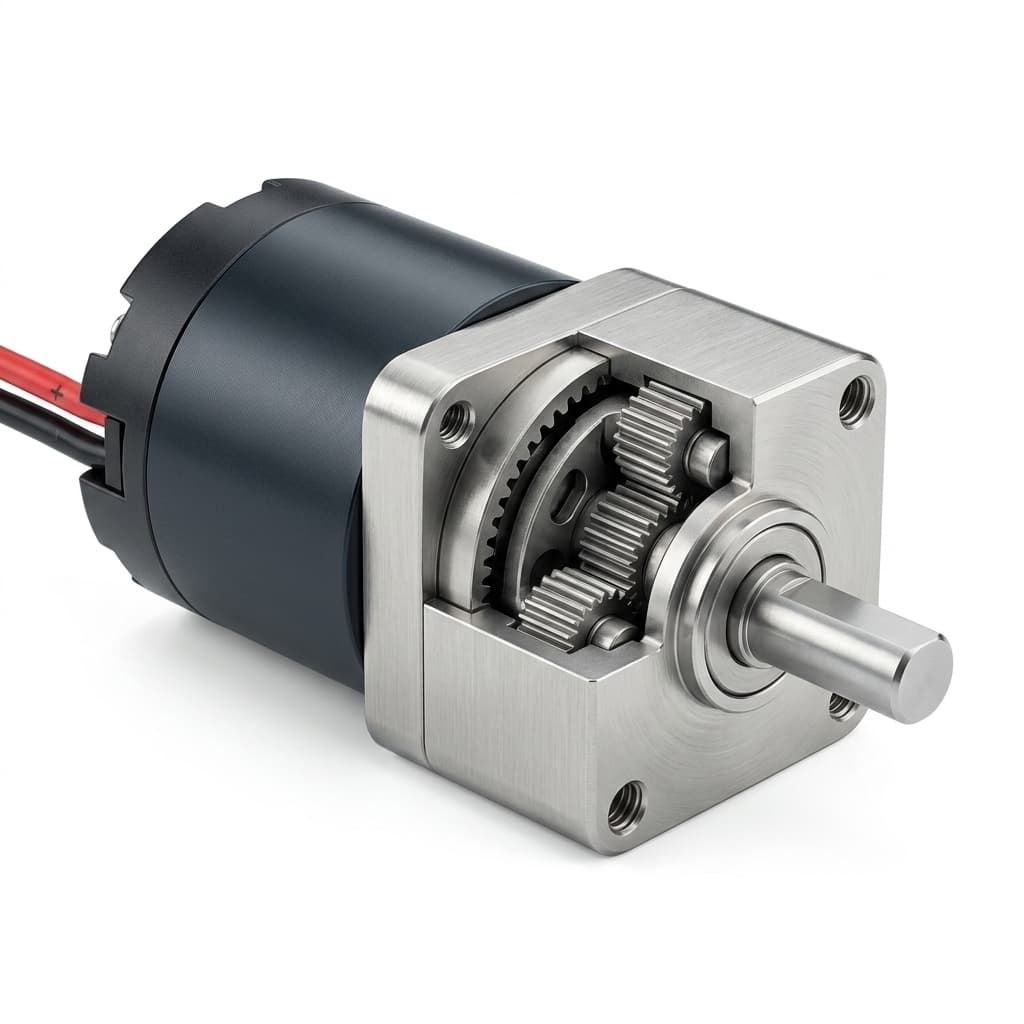
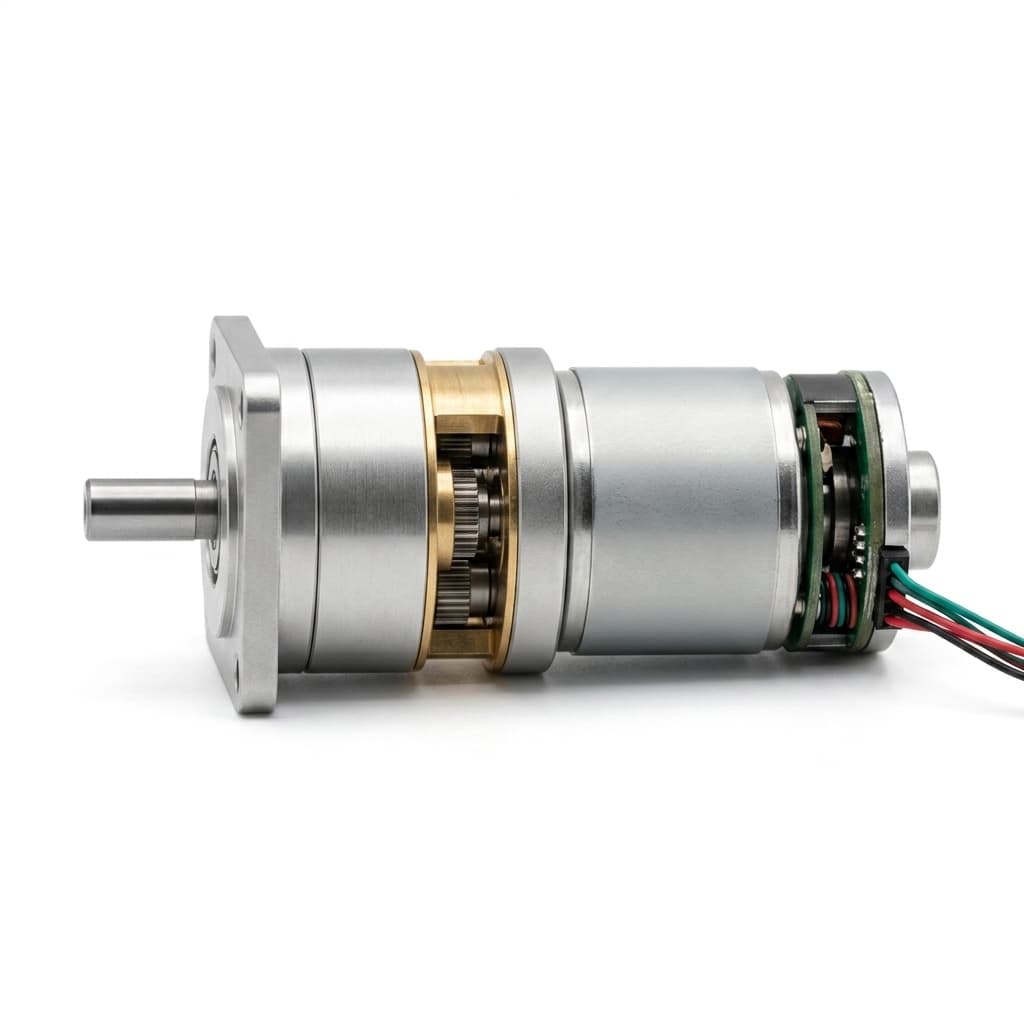
Integrated encoder planetary gearmotor showing cable exit and gearbox package
Compact encoder gear motor for optical positioning and smart actuator feedback
Micro planetary gear motor with encoder assembly for speed and position validation
Encoder planetary drive sample for AGV auxiliary axes and automated equipment
BLDC planetary motor with feedback-ready rear cap for precision drive projects

Buyer FAQ

What types of encoders do you use?

We typically use magnetic Hall-effect encoders for robustness against dust and oil, but optical encoders are available for high precision.

Can I get a Z-index pulse?

Yes, 3-channel (A/B/Z) encoders are available upon request for absolute homing.

Do you provide the mating connector?

Yes, every sample is shipped with a flying-lead mating wire harness for immediate testing.

Can encoder feedback be placed on the gearbox output?

Output-side feedback can be reviewed when the package has enough space and the buyer defines repeatability, backlash, connector, and inspection requirements.

Related Resources

  • Premium Brand Alternative Review
  • Backlash Measurement Guide
  • Low Backlash Planetary Motors
  • Optical Instrument Applications
  • Contact Sales Engineering

Product Qualification Review

Ready for a Product-Specific OEM Review?

Send the target size, voltage, torque, speed, ratio, quantity, drawing status, and validation concerns. Sales engineering can then confirm whether this product family is the right starting point or whether another frame, gear material, or OEM assembly route is safer.

WhatsApp: +86 18857971991. Email: [email protected].

WhatsApp ReviewSend RFQQuality Evidence

Inquiry Email

[email protected]

Email app

Include OD/length, voltage, torque, loaded speed, ratio, drawings, quantity, and destination.

Instant Chat

+86 18857971991

Chat on WhatsApp

Fast channel for clarifying specs, drawings, and sample timing.