LogoMicro Planetary Motor
Start inquiry
LogoMicro Planetary Motor
WhatsApp
LogoMicro Planetary Motor

China-based industrial OEM supplier supporting customization, quality control, and global delivery.

Inquiry Email

[email protected]

Email app

Include OD/length, voltage, torque, loaded speed, ratio, drawings, quantity, and destination.

Instant Chat

+86 18857971991

Chat on WhatsApp

Fast channel for clarifying specs, drawings, and sample timing.

Products
  • Product Overview
  • Micro DC Planetary Gear Motor
  • Micro BLDC Planetary Gear Motor
  • Encoder Micro Planetary Gear Motor
  • Miniature Planetary Gearboxes
  • Custom OEM Drive Assemblies
  • Coreless Micro Planetary Motors
  • Low Backlash Planetary Motors
  • Low Noise Micro Planetary Motors
  • High Torque Miniature Motors
  • Metal Gear Planetary Drives
Solutions
  • Solutions Overview
  • Robotics & AGV
  • Medical Devices
  • Smart Lock Actuators
  • Valve Actuators
  • Optical Instruments
  • Industrial Automation
OEM Capabilities
  • OEM Overview
  • Custom Engineering
  • Gear Machining
  • Testing & Validation
  • Export & Logistics
Resources
  • CAD / STEP Request
  • Ratio & Torque Calculator
  • POM vs MIM Gear Materials
  • Premium Brand Alternatives
  • Blog
  • About
  • Contact / RFQ
  • Quality & Testing
  • Privacy Policy
  • Cookie Policy
  • Terms of Service
© 2026 Micro Planetary Motor. All Rights Reserved.|Micro Planetary Motor is the micro drive product site operated by Linkup Ai Co., Ltd.; manufacturing programs are coordinated through the Linkup Precision manufacturing network.|Traceable process checks | RoHS, REACH, and applicable CE file support by project scope
← Back to Solutions

Optical Instruments

Low-backlash 6mm, 10mm, and 12mm micro planetary gear motors with encoder, Hall, indexed-drive, and low-noise options for lens focus, filter wheels, aperture modules, camera positioning, surveying instruments, and compact lab optics.

Target Buyer:For optical and instrument OEMs that need repeatable small-angle motion, quiet operation, compact length, and feedback-ready cable integration rather than catalog peak torque alone.
Discuss on WhatsAppSend RFQEmail specsRequest CAD / STEP

Solution recommendations are confirmed by RFQ after the real load, envelope, quantity, and validation scope are reviewed.

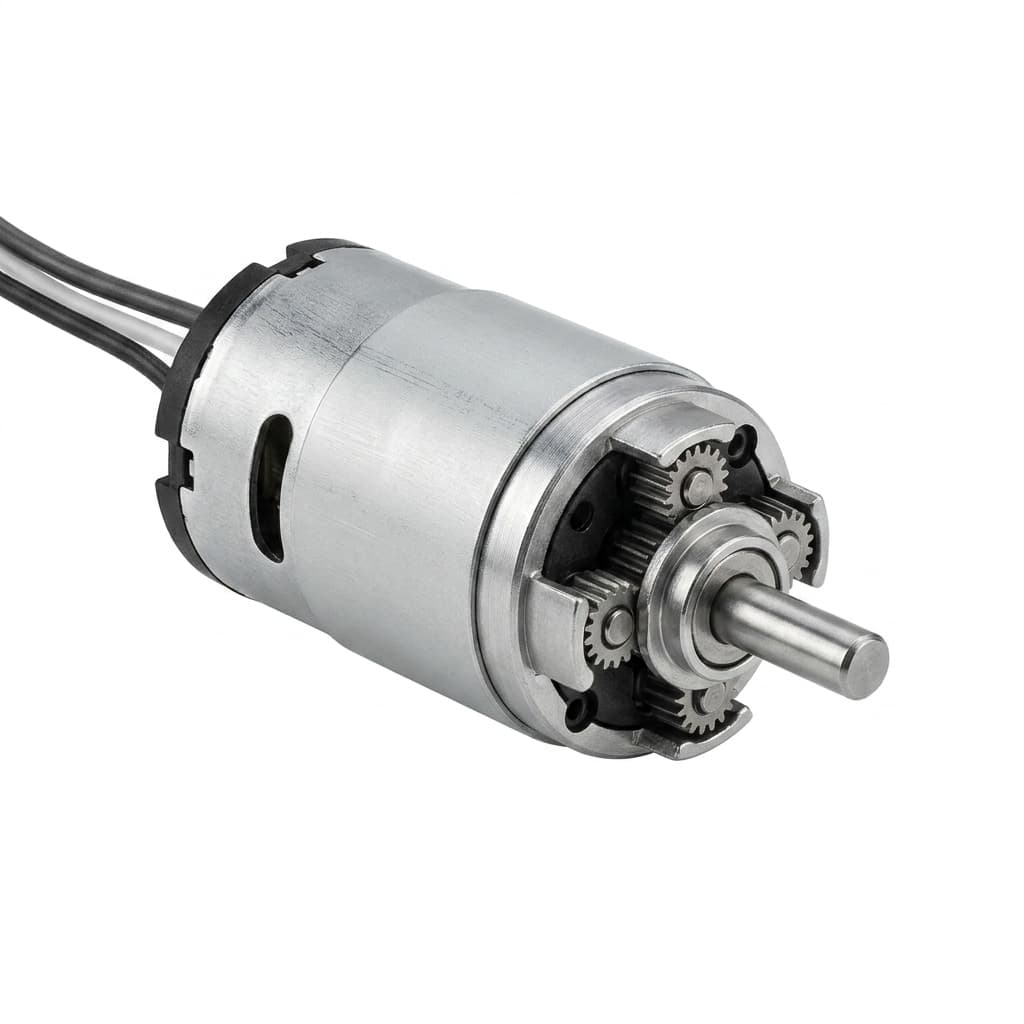
Encoder micro planetary gear motor for lens focus and filter wheel positioning

Solution Highlights

  • Low backlash and repeatability targets for lens, filter, and iris positioning
  • Encoder, Hall, and indexed-drive options for closed-loop or repeatable motion
  • Low-noise and low-vibration builds with POM, hybrid, or metal gear review
  • Custom shaft, flange, cable, and connector integration for compact optical envelopes

Common Use Cases

  • Lens Focus Drives
  • Filter Wheels
  • Iris and Aperture Actuators
  • Security Camera PTZ Modules
  • Surveying and Metrology Instruments
  • Lab Analyzer Stages
  • Portable Optical Instruments

Implementation Focus

  • Backlash, lost motion, and repeatability after direction reversal
  • Positioning resolution from gear ratio, motor type, encoder count, and controller limits
  • Low-speed ripple, vibration, and settling behavior near the optical element
  • Low-noise material, grease, bearing, and preload choices for portable instruments
  • Encoder, Hall, limit switch, cable exit, and pinout integration
  • Custom shaft, flange, bracket, and motor length constraints inside optical housings
  • Homing, calibration, thermal drift, and repeatability over life testing

Application Buyer Review Path

Align Fit, Control, Supply, and Quality Before Sampling

Application buyers usually need more than a product suggestion. Use this review path to connect mechanical fit, controls, quote scope, and validation evidence before a sample is approved.

Buyer RoleDecision CheckPage EvidenceNext Step
Mechanical / System EngineeringLoad path, available OD and length, shaft datum, flange geometry, cable exit, radial load, and mating CAD revision.Application intake, implementation focus, selection logic, CAD/STEP panel, and related product routes.Request CAD / STEP
Electrical / ControlsVoltage window, current limit, driver type, feedback signal, EMI concern, braking behavior, and duty cycle.Evaluation matrix, feedback route, validation package, and sample test evidence request.Review encoder options
Procurement / ProgramPrototype quantity, annual volume, sample timing, quote scope, destination, and approved supplier workflow.RFQ checklist, WhatsApp handoff, email template, export file scope, and related OEM support links.Send RFQ
Quality / NPIDrawing revision, CTQ dimensions, torque-speed test condition, noise/backlash method, EOL limits, and lot traceability.Production and QC flow, risk controls, validation package, and buyer-defined evidence scope.Quality evidence

Mechanical / System Engineering

Decision Check
Load path, available OD and length, shaft datum, flange geometry, cable exit, radial load, and mating CAD revision.
Page Evidence
Application intake, implementation focus, selection logic, CAD/STEP panel, and related product routes.
Next Step
Request CAD / STEP

Electrical / Controls

Decision Check
Voltage window, current limit, driver type, feedback signal, EMI concern, braking behavior, and duty cycle.
Page Evidence
Evaluation matrix, feedback route, validation package, and sample test evidence request.
Next Step
Review encoder options

Procurement / Program

Decision Check
Prototype quantity, annual volume, sample timing, quote scope, destination, and approved supplier workflow.
Page Evidence
RFQ checklist, WhatsApp handoff, email template, export file scope, and related OEM support links.
Next Step
Send RFQ

Quality / NPI

Decision Check
Drawing revision, CTQ dimensions, torque-speed test condition, noise/backlash method, EOL limits, and lot traceability.
Page Evidence
Production and QC flow, risk controls, validation package, and buyer-defined evidence scope.
Next Step
Quality evidence

Application RFQ Intake

Translate the Application Into Motor Selection Inputs

The first review should capture load, speed, space, validation, and compliance constraints, not just a motor part number. This keeps the recommended gear ratio, shaft, feedback, and test plan tied to the real machine.

RFQ InputExamples to ProvideEngineering Output
Load and motion profileContinuous torque, peak torque, stall/jam event, stroke, angle, wheel load, or pump cycle.Frames the motor diameter, winding, ratio, gear material, and torque reserve before sample selection.
Speed, timing, and ratio boundaryNo-load RPM, loaded output RPM, actuation time, known ratio, or acceptable speed tolerance.Creates the candidate ratio table with rated-load speed, current, efficiency, and thermal expectation.
Noise, backlash, and repeatabilitydB limit, measurement distance, arcmin or degree backlash target, reversing frequency, positioning need.Separates POM, hybrid, metal, low-backlash, encoder, and Hall-feedback paths early.
Envelope and interface controlTarget OD, max length, shaft drawing, flange datum, cable exit, connector, mating CAD revision.Prevents CAD/STEP mismatch and keeps shaft, mounting, harness, and packaging changes visible.
Validation and production scopePrototype quantity, annual volume, life target, destination, RoHS/REACH, ISO file, packing rules.Defines sample evidence, EOL test limits, compliance files, lead time, and production quote assumptions.

Load and motion profile

Examples to Provide
Continuous torque, peak torque, stall/jam event, stroke, angle, wheel load, or pump cycle.
Engineering Output
Frames the motor diameter, winding, ratio, gear material, and torque reserve before sample selection.

Speed, timing, and ratio boundary

Examples to Provide
No-load RPM, loaded output RPM, actuation time, known ratio, or acceptable speed tolerance.
Engineering Output
Creates the candidate ratio table with rated-load speed, current, efficiency, and thermal expectation.

Noise, backlash, and repeatability

Examples to Provide
dB limit, measurement distance, arcmin or degree backlash target, reversing frequency, positioning need.
Engineering Output
Separates POM, hybrid, metal, low-backlash, encoder, and Hall-feedback paths early.

Envelope and interface control

Examples to Provide
Target OD, max length, shaft drawing, flange datum, cable exit, connector, mating CAD revision.
Engineering Output
Prevents CAD/STEP mismatch and keeps shaft, mounting, harness, and packaging changes visible.

Validation and production scope

Examples to Provide
Prototype quantity, annual volume, life target, destination, RoHS/REACH, ISO file, packing rules.
Engineering Output
Defines sample evidence, EOL test limits, compliance files, lead time, and production quote assumptions.

Application Evaluation Matrix

Evaluation MetricTypical RangeBuyer Relevance
Backlash and Lost MotionProject-defined arcmin targetDefines acceptable position error after reversal before selecting gear ratio, gear material, preload, and measurement method.
Positioning ResolutionEncoder count + gearbox ratioCombines motor type, encoder CPR, gearbox ratio, and controller pulse handling to meet the optical resolution target.
Low-Speed StabilitySmooth loaded motionHelps focus, aperture, and filter motion settle without disturbing image or measurement stability.
Noise and VibrationMaterial and drive dependentPOM, hybrid, and metal gear choices must be checked against acoustic limits, vibration sensitivity, torque, and life.
Frame and Envelope6mm / 10mm / 12mm classes6mm drives fit miniature focus modules, while 10mm and 12mm drives add torque and assembly margin for compact instruments.
Feedback IntegrationEncoder, Hall, or open-loopCable routing, connector pinout, signal format, and inspection fixtures affect closed-loop reliability.
Thermal and Calibration DriftApplication validatedStored optical calibration maps need repeatability after warm-up, temperature cycling, and life testing.

Backlash and Lost Motion

Typical Range
Project-defined arcmin target
Buyer Relevance
Defines acceptable position error after reversal before selecting gear ratio, gear material, preload, and measurement method.

Positioning Resolution

Typical Range
Encoder count + gearbox ratio
Buyer Relevance
Combines motor type, encoder CPR, gearbox ratio, and controller pulse handling to meet the optical resolution target.

Low-Speed Stability

Typical Range
Smooth loaded motion
Buyer Relevance
Helps focus, aperture, and filter motion settle without disturbing image or measurement stability.

Noise and Vibration

Typical Range
Material and drive dependent
Buyer Relevance
POM, hybrid, and metal gear choices must be checked against acoustic limits, vibration sensitivity, torque, and life.

Frame and Envelope

Typical Range
6mm / 10mm / 12mm classes
Buyer Relevance
6mm drives fit miniature focus modules, while 10mm and 12mm drives add torque and assembly margin for compact instruments.

Feedback Integration

Typical Range
Encoder, Hall, or open-loop
Buyer Relevance
Cable routing, connector pinout, signal format, and inspection fixtures affect closed-loop reliability.

Thermal and Calibration Drift

Typical Range
Application validated
Buyer Relevance
Stored optical calibration maps need repeatability after warm-up, temperature cycling, and life testing.

Sample Qualification Plan

Convert This Use Case Into Pass/Fail Evidence

These checks help engineering, procurement, and quality teams turn the application discussion into sample acceptance criteria before CAD freeze or pilot procurement.

WorkstreamBuyer QuestionEvidence to PreparePass Signal
Backlash and repeatabilityWill the optical mechanism return to target position after reversal, homing, and repeated moves?Allowed optical error, backlash target, preload, travel angle, homing method, and measurement fixture.Lost motion and repeatability stay within the optical error budget under the agreed preload and direction changes.
Low-speed smoothnessWill ripple, vibration, or settling disturb focus, aperture, filter, or sensor output?Move profile, acceleration limit, optical load, vibration sensitivity, noise target, and controller current limit.Motion settles inside the target window without visible image shift or measurement instability in the buyer fixture.
Feedback and calibration recoveryCan encoder, Hall, index, or homing behavior recover position after power cycle or calibration routine?Feedback type, CPR, signal voltage, pinout, cable shielding, homing logic, and EOL signal criteria.Position signal and homing sequence remain repeatable after power cycle, temperature change, and cable movement.
Cleanliness and thermal driftWill grease, material, heat, or cable stress affect lenses, filters, sensors, or calibration maps?Grease constraint, cleanliness expectation, temperature range, warm-up profile, cable route, and housing CAD.No visible contamination path, calibration drift, or cable strain issue appears after the agreed operating cycle.

Backlash and repeatability

Buyer Question
Will the optical mechanism return to target position after reversal, homing, and repeated moves?
Evidence to Prepare
Allowed optical error, backlash target, preload, travel angle, homing method, and measurement fixture.
Pass Signal
Lost motion and repeatability stay within the optical error budget under the agreed preload and direction changes.

Low-speed smoothness

Buyer Question
Will ripple, vibration, or settling disturb focus, aperture, filter, or sensor output?
Evidence to Prepare
Move profile, acceleration limit, optical load, vibration sensitivity, noise target, and controller current limit.
Pass Signal
Motion settles inside the target window without visible image shift or measurement instability in the buyer fixture.

Feedback and calibration recovery

Buyer Question
Can encoder, Hall, index, or homing behavior recover position after power cycle or calibration routine?
Evidence to Prepare
Feedback type, CPR, signal voltage, pinout, cable shielding, homing logic, and EOL signal criteria.
Pass Signal
Position signal and homing sequence remain repeatable after power cycle, temperature change, and cable movement.

Cleanliness and thermal drift

Buyer Question
Will grease, material, heat, or cable stress affect lenses, filters, sensors, or calibration maps?
Evidence to Prepare
Grease constraint, cleanliness expectation, temperature range, warm-up profile, cable route, and housing CAD.
Pass Signal
No visible contamination path, calibration drift, or cable strain issue appears after the agreed operating cycle.

Product Family Routing

Route This Application to the Right Motor Family

A solution page should make the next product review obvious. Match the dominant application signal to a product family, then send the listed inputs so engineering can confirm the route.

Application SignalRecommended Product RouteInputs to ConfirmReview
High torque, shock load, wheel load, breakaway torque, or jam conditionHigh-torque miniature gear motors or metal gear micro planetary drives with reinforced gear stack review.Share continuous torque, peak torque, stall time, shaft load, duty cycle, and current limit.High torque motors
Quiet patient-adjacent, indoor, optical, or residential motion targetLow-noise, coreless, POM, or hybrid gear stage route before moving to metal gears.Share dB limit, measurement distance, enclosure condition, load, temperature, and life target.Low noise motors
Positioning, odometry, repeatability, stall detection, or closed-loop controlEncoder or Hall-feedback planetary gear motor with defined signal and EOL checks.Share CPR, signal voltage, controller input, cable route, pinout, and target resolution.Encoder motors
Custom shaft, flange, connector, harness, bracket, or module packagingCustom OEM micro drive assembly with drawing revision, tooling boundary, and production handoff.Attach mating drawing, shaft profile, flange datum, connector model, packing rule, and annual volume.OEM assemblies
Material, backlash, noise, and durability tradeoff is not frozenPOM, hybrid, MIM metal, or low-backlash route reviewed against the real application load.Share noise target, reversing frequency, backlash limit, shock condition, grease concern, and cost band.Material guide

High torque, shock load, wheel load, breakaway torque, or jam condition

Recommended Product Route
High-torque miniature gear motors or metal gear micro planetary drives with reinforced gear stack review.
Inputs to Confirm
Share continuous torque, peak torque, stall time, shaft load, duty cycle, and current limit.
Review
High torque motors

Quiet patient-adjacent, indoor, optical, or residential motion target

Recommended Product Route
Low-noise, coreless, POM, or hybrid gear stage route before moving to metal gears.
Inputs to Confirm
Share dB limit, measurement distance, enclosure condition, load, temperature, and life target.
Review
Low noise motors

Positioning, odometry, repeatability, stall detection, or closed-loop control

Recommended Product Route
Encoder or Hall-feedback planetary gear motor with defined signal and EOL checks.
Inputs to Confirm
Share CPR, signal voltage, controller input, cable route, pinout, and target resolution.
Review
Encoder motors

Custom shaft, flange, connector, harness, bracket, or module packaging

Recommended Product Route
Custom OEM micro drive assembly with drawing revision, tooling boundary, and production handoff.
Inputs to Confirm
Attach mating drawing, shaft profile, flange datum, connector model, packing rule, and annual volume.
Review
OEM assemblies

Material, backlash, noise, and durability tradeoff is not frozen

Recommended Product Route
POM, hybrid, MIM metal, or low-backlash route reviewed against the real application load.
Inputs to Confirm
Share noise target, reversing frequency, backlash limit, shock condition, grease concern, and cost band.
Review
Material guide

Selection Logic

Decision PointRecommended PathValidation Input
6mm versus 10mm and 12mm frame sizeUse 6mm drives for miniature focus mechanisms and portable optical modules; move to 10mm and 12mm options when PTZ, surveying, metrology, or lab instruments need more torque and assembly margin.Available diameter, gearbox length, shaft location, cable path, torque load, move time, and life target.
Backlash target versus correction strategyTranslate the optical error budget into allowable output lost motion, then decide whether low-backlash gearing, preload, encoder correction, or repeatable homing is required.Backlash target in arcmin, reversal frequency, preload, measurement method, and allowable optical error.
Gear ratio versus settling timeSelect enough ratio for torque and resolution, but avoid excessive reduction that makes moves slow or increases reflected friction.Travel angle, target speed, move time, acceleration limit, holding torque, and controller current limit.
Encoder or Hall feedback versus open-loop indexingUse open-loop indexed motion for simple mechanisms; choose encoder or Hall feedback when position confirmation, stall detection, or calibration recovery is required.Encoder CPR, Hall logic, controller input, cable length, connector, shielding, and target positioning resolution.
Low-noise material choice near optical elementsReview POM, hybrid, and metal gear stacks together with grease, bearing support, and preload instead of choosing by material name alone.Torque, backlash, noise target, vibration sensitivity, temperature range, cleanliness expectation, and life target.

6mm versus 10mm and 12mm frame size

Recommended Path
Use 6mm drives for miniature focus mechanisms and portable optical modules; move to 10mm and 12mm options when PTZ, surveying, metrology, or lab instruments need more torque and assembly margin.
Validation Input
Available diameter, gearbox length, shaft location, cable path, torque load, move time, and life target.

Backlash target versus correction strategy

Recommended Path
Translate the optical error budget into allowable output lost motion, then decide whether low-backlash gearing, preload, encoder correction, or repeatable homing is required.
Validation Input
Backlash target in arcmin, reversal frequency, preload, measurement method, and allowable optical error.

Gear ratio versus settling time

Recommended Path
Select enough ratio for torque and resolution, but avoid excessive reduction that makes moves slow or increases reflected friction.
Validation Input
Travel angle, target speed, move time, acceleration limit, holding torque, and controller current limit.

Encoder or Hall feedback versus open-loop indexing

Recommended Path
Use open-loop indexed motion for simple mechanisms; choose encoder or Hall feedback when position confirmation, stall detection, or calibration recovery is required.
Validation Input
Encoder CPR, Hall logic, controller input, cable length, connector, shielding, and target positioning resolution.

Low-noise material choice near optical elements

Recommended Path
Review POM, hybrid, and metal gear stacks together with grease, bearing support, and preload instead of choosing by material name alone.
Validation Input
Torque, backlash, noise target, vibration sensitivity, temperature range, cleanliness expectation, and life target.

Production and QC Flow

StageControl PointBuyer Evidence
Optical motion requirement reviewMap the lens, filter, iris, PTZ, or instrument-stage requirement into torque, speed, backlash, resolution, noise, vibration, and envelope targets.Mechanism drawing, motion profile, optical error budget, backlash target, feedback need, and available motor envelope.
Interface and DFM freezeConfirm shaft, flange, cable exit, connector, encoder signals, controller limits, grease, and assembly constraints before prototype quotation.2D/3D drawing revision, shaft and flange detail, cable route, pinout, controller input, and sample BOM option.
Optical-load sample validationMeasure backlash, repeatability, low-speed stability, acoustic output, vibration, current, temperature rise, and encoder signal quality using the real optical load.Sample test report with load condition, voltage, temperature, backlash method, vibration notes, and feedback signal checks.
Pilot run and EOL limitsSet inspection limits for rotation direction, no-load current, noise, backlash or lost motion, encoder output, cable routing, and traceability.EOL checklist, inspection fixture notes, cable routing standard, lot label plan, and outgoing quality record.
Production revision controlLock drawings, BOM, grease, material choices, cable specification, inspection records, and change-control process before recurring OEM supply.Approved drawing package, BOM revision, material and grease record, inspection limits, and change notice process.

Optical motion requirement review

Control Point
Map the lens, filter, iris, PTZ, or instrument-stage requirement into torque, speed, backlash, resolution, noise, vibration, and envelope targets.
Buyer Evidence
Mechanism drawing, motion profile, optical error budget, backlash target, feedback need, and available motor envelope.

Interface and DFM freeze

Control Point
Confirm shaft, flange, cable exit, connector, encoder signals, controller limits, grease, and assembly constraints before prototype quotation.
Buyer Evidence
2D/3D drawing revision, shaft and flange detail, cable route, pinout, controller input, and sample BOM option.

Optical-load sample validation

Control Point
Measure backlash, repeatability, low-speed stability, acoustic output, vibration, current, temperature rise, and encoder signal quality using the real optical load.
Buyer Evidence
Sample test report with load condition, voltage, temperature, backlash method, vibration notes, and feedback signal checks.

Pilot run and EOL limits

Control Point
Set inspection limits for rotation direction, no-load current, noise, backlash or lost motion, encoder output, cable routing, and traceability.
Buyer Evidence
EOL checklist, inspection fixture notes, cable routing standard, lot label plan, and outgoing quality record.

Production revision control

Control Point
Lock drawings, BOM, grease, material choices, cable specification, inspection records, and change-control process before recurring OEM supply.
Buyer Evidence
Approved drawing package, BOM revision, material and grease record, inspection limits, and change notice process.

Design Freeze Risk Check

Failure Modes to Close Before Pilot Release

Most application failures are not caused by the gear ratio alone. Close these checks before the motor family, drawing revision, and validation method are locked.

Failure ModeEarly SignalPrevention
Torque reserve disappears after the real fixture is installedNo-load speed looks acceptable, but current rises or motion stalls under seal friction, wheel load, spring force, or end-stop impact.Quote against continuous, peak, and stall conditions with voltage sag, current limit, duty cycle, and thermal path included.
CAD fit passes once, then fails after shaft or connector revisionThe gearbox OD fits the enclosure, but the shaft flat, flange datum, cable exit, connector, or bend radius changes late.Freeze drawing revision, mating CAD, cable route, shaft datum, and connector clearance before pilot release.
Noise or backlash is rejected because the method was unclearBuyer and supplier use different load, distance, preload, fixture, background noise, or backlash measurement conditions.Define dB distance, load fixture, backlash preload, direction changes, and pass/fail limit before sample testing.
Thermal, EMI, or feedback issues appear only in pilot buildBench samples pass, but enclosure heat path, controller current limit, cable routing, or encoder signal quality changes in the real device.Validate the motor with buyer-like enclosure, driver, cable route, duty profile, and EOL signal checks.
Approved samples drift when the program moves to productionPrototype BOM, gear material, grease, label, packing, or EOL limit is not tied to an approved revision.Keep approved sample record, BOM option, drawing revision, EOL criteria, lot labels, and outgoing inspection plan together.

Torque reserve disappears after the real fixture is installed

Early Signal
No-load speed looks acceptable, but current rises or motion stalls under seal friction, wheel load, spring force, or end-stop impact.
Prevention
Quote against continuous, peak, and stall conditions with voltage sag, current limit, duty cycle, and thermal path included.

CAD fit passes once, then fails after shaft or connector revision

Early Signal
The gearbox OD fits the enclosure, but the shaft flat, flange datum, cable exit, connector, or bend radius changes late.
Prevention
Freeze drawing revision, mating CAD, cable route, shaft datum, and connector clearance before pilot release.

Noise or backlash is rejected because the method was unclear

Early Signal
Buyer and supplier use different load, distance, preload, fixture, background noise, or backlash measurement conditions.
Prevention
Define dB distance, load fixture, backlash preload, direction changes, and pass/fail limit before sample testing.

Thermal, EMI, or feedback issues appear only in pilot build

Early Signal
Bench samples pass, but enclosure heat path, controller current limit, cable routing, or encoder signal quality changes in the real device.
Prevention
Validate the motor with buyer-like enclosure, driver, cable route, duty profile, and EOL signal checks.

Approved samples drift when the program moves to production

Early Signal
Prototype BOM, gear material, grease, label, packing, or EOL limit is not tied to an approved revision.
Prevention
Keep approved sample record, BOM option, drawing revision, EOL criteria, lot labels, and outgoing inspection plan together.

Validation Package

Evidence Buyers Can Request Before Pilot Release

Application pages should lead toward drawings, sample evidence, and production assumptions. These files are scoped during RFQ so buyers know what can be verified before design freeze.

EvidenceWhat It IncludesBuyer Use
Performance checkVoltage, no-load speed, rated-load speed, current, torque point, ratio, and temperature note.Confirms the selected motor matches the required operating point before pilot procurement.
Mechanical file setOutline drawing, shaft/flange revision, STEP/IGES availability, cable exit, connector, and label notes.Lets mechanical teams freeze enclosure, mating part, harness route, and incoming inspection dimensions.
Application-specific test noteNoise, backlash, cycle life, thermal rise, radial load, EMI, or holding-force check as required.Turns the market- or device-specific concern into a measurable sample approval criterion.
Production and export fileBOM option, EOL speed/current limits, RoHS/REACH or buyer file scope, packing, shipment destination.Keeps repeat orders aligned after prototype approval and reduces qualification drift.

Performance check

What It Includes
Voltage, no-load speed, rated-load speed, current, torque point, ratio, and temperature note.
Buyer Use
Confirms the selected motor matches the required operating point before pilot procurement.

Mechanical file set

What It Includes
Outline drawing, shaft/flange revision, STEP/IGES availability, cable exit, connector, and label notes.
Buyer Use
Lets mechanical teams freeze enclosure, mating part, harness route, and incoming inspection dimensions.

Application-specific test note

What It Includes
Noise, backlash, cycle life, thermal rise, radial load, EMI, or holding-force check as required.
Buyer Use
Turns the market- or device-specific concern into a measurable sample approval criterion.

Production and export file

What It Includes
BOM option, EOL speed/current limits, RoHS/REACH or buyer file scope, packing, shipment destination.
Buyer Use
Keeps repeat orders aligned after prototype approval and reduces qualification drift.

CAD / STEP Request

Request Outline Drawings Before You Freeze the Mechanical Design

Share the mating envelope and target duty data so sales engineering can confirm whether an existing outline drawing, STEP/IGES file, or custom shaft and flange proposal is suitable for your project.

1

Installation envelope, mounting pattern, shaft interface, and cable exit.

2

Voltage, loaded speed, torque, gear ratio, duty cycle, noise, and backlash limits.

3

Preferred CAD format, drawing revision, prototype quantity, destination, and compliance notes.

Fields engineering checks before sharing a model

Product fit
Diameter, gearbox length, motor family, shaft style, flange pattern, and cable or connector exit.
Performance target
Voltage, loaded speed, continuous torque, peak or stall torque, ratio, duty cycle, life, noise, and backlash.
Mechanical interface
Mating drawing revision, installation clearance, radial or axial load, tolerance priority, and assembly sequence.
Release package
2D outline, STEP/IGES envelope, custom shaft/flange review, datasheet values, and quality evidence scope.

Useful before CAD freeze

Estimate ratio and torque firstCompare POM, hybrid, and metal gearsAlign quality evidence scope
Email CAD requestWhatsApp engineeringOpen CAD request form

CAD files are shared by project fit and revision status. For custom shafts, flanges, cable routing, or gearbox interfaces, attach the mating drawing so the first CAD exchange uses the correct mechanical boundary.

RFQ Preparation Checklist

  1. Optical mechanism type: lens focus, zoom, filter wheel, iris, PTZ, or instrument stage
  2. Maximum backlash or lost motion target in arcmin plus repeatability or resolution target
  3. Travel angle or stroke, move time, target speed, and allowable settling time
  4. Load torque, friction, preload, holding torque, and any external gear or screw load
  5. Voltage, current limit, controller type, noise limit, and vibration sensitivity
  6. Feedback type, encoder CPR or pulse count, Hall signals, interface, cable length, and connector
  7. Motor diameter, gearbox length, output shaft geometry, flat/D-cut, thread, and flange pattern
  8. Duty cycle, temperature range, life target, cleanliness, grease, and sample validation plan

Risk and Mitigation

  • Position error after reversal: Measure backlash and lost motion with the actual optical load, preload, direction changes, and controller profile.
  • Vibration affecting optical output: Test low-speed ripple, mounting stiffness, gear material, and acceleration profile while monitoring image or measurement stability.
  • Feedback signal or pinout mismatch: Freeze encoder CPR, channels, Hall logic, connector pinout, cable exit, shielding, and inspection fixtures before pilot builds.
  • Grease migration or contamination: Review grease, material, sealing, orientation, and cleanliness expectations when motors sit near lenses, filters, or sensors.
  • Slow settling from excessive ratio: Balance torque margin, ratio, motor type, and acceleration limits against the required move time and settling window.
  • Calibration drift over temperature or life: Run warm-up, temperature, and life checks, then define calibration, homing, and end-of-line acceptance rules.
  • Cable strain inside compact housings: Confirm cable length, exit angle, strain relief, flex path, and connector orientation together with the optical housing CAD.

Recommended Products

Low-vibration micro planetary gear motor for filter wheel and aperture indexing
Integrated encoder planetary gear motor for precision optical instruments
6mm micro planetary gear motor for compact optical focus modules
Low-noise micro planetary gear motor for portable instrument positioning

Buyer FAQ

What backlash should we specify for a lens or filter wheel drive?

Start with the allowed optical error, translate it to output shaft movement in arcmin or degrees, then confirm whether low-backlash gearing, preload, encoder correction, or a homing routine is required.

Can you integrate encoder feedback for optical instruments?

Yes. We can review encoder CPR, signal format, Hall signals, cable exit, connector, shielding, and assembly inspection so the drive is easier to integrate into a closed-loop optical module.

Should an optical drive use POM, hybrid, or metal gears?

POM can help with noise and smooth feel at lighter loads, metal supports higher torque and life margins, and hybrid stacks may balance both. The right choice depends on torque, backlash, temperature, acoustic target, and validation results.

When should we use 6mm, 10mm, or 12mm micro planetary motors?

6mm motors fit miniature focus and portable modules with tight space limits. 10mm and 12mm frames add torque and assembly margin for camera PTZ, surveying, metrology, and lab instrument mechanisms.

Which validation tests matter before optical pilot production?

Backlash, repeatability, noise, vibration, current, temperature rise, encoder signal quality, homing behavior, life, and end-of-line acceptance limits should be checked with the real optical load.

What information makes an RFQ actionable?

Share mechanism type, motion profile, torque or load estimate, backlash/resolution target, voltage/current limits, diameter and length limits, shaft/flange drawing, feedback requirements, noise target, and expected annual volume.

Related Resources

  • Backlash Measurement Guide for Micro Gearboxes
  • Encoder Micro Planetary Gear Motor
  • Low Backlash Micro Planetary Gear Motors
  • Low Noise Micro Planetary Motors
  • Coreless Micro Planetary Gear Motors
  • Custom Shaft & Flange
  • Testing & Validation
  • POM vs MIM Metal Gear Material Guide
  • Gear Ratio & Torque Calculator
  • Contact Sales Engineering

Application Qualification Review

Ready to Qualify This Application?

Send the application module, target load, speed, torque, envelope, voltage, quantity, drawing status, and validation concerns. Sales engineering can then confirm whether this solution route, another product family, or an OEM assembly path is safer.

WhatsApp: +86 18857971991. Email: [email protected].

WhatsApp ReviewSend RFQRequest CAD / STEP

Inquiry Email

[email protected]

Email app

Include OD/length, voltage, torque, loaded speed, ratio, drawings, quantity, and destination.

Instant Chat

+86 18857971991

Chat on WhatsApp

Fast channel for clarifying specs, drawings, and sample timing.